PHONE: (847) 253-6000
TOLL FREE: (800) 52-MOTOR
Explore our industrial-grade brushless motors, heavy-duty traction powerplants, micro-actuators, and precision motor housings. Engineered for high continuous torque, extreme efficiency, and long operational lifespans under rigorous duty cycles.
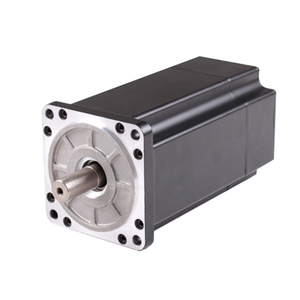
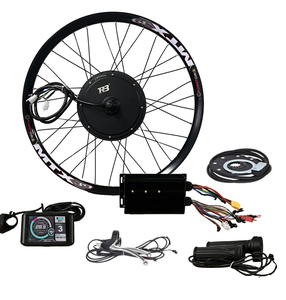
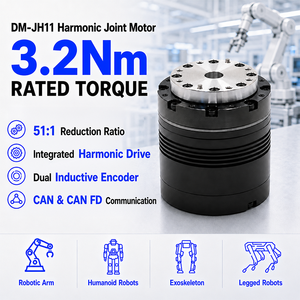
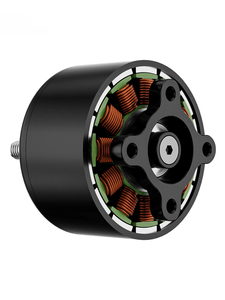
As modern electromechanical systems transition toward direct-drive mechanisms, the demand for high-density, low-cogging direct torque motors has surged. As a premier China torque motor manufacturer and custom factory, our enterprise bridges seven decades of foundational electromagnetic engineering—inherited from rigorous American fractional horsepower (FHP) motor heritage dating back to 1954—with ultra-modern, vertically integrated Chinese manufacturing ecosystems.
Unlike standard induction or high-speed brushed motors that rely heavily on complex, wear-prone mechanical gearboxes, high-torque direct-drive motors deliver maximum continuous torque at zero or low rotational speeds. By eliminating mechanical gear backlash, belt compliance, and friction losses, our torque motor assemblies achieve unprecedented positioning accuracy, immediate dynamic response, and whisper-quiet acoustic signatures.
Utilizing high-slot-fill precision automatic needle winding and rare-earth Neodymium (NdFeB) permanent magnets rated up to N52SH, our stators generate extraordinary magnetic flux density without thermal saturation.
By coupling the hollow-shaft motor rotor directly to the driven load, systems eliminate mechanical hysterics, reducing total cost of ownership (TCO) while maximizing servo bandwidth and control stiffness.
Operating under certified ISO 9001:2015 and medical-device standard ISO 13485:2016 quality controls, our wound stators utilize Class H (180°C) vacuum pressure impregnated (VPI) insulation for extreme thermal endurance.
Selecting the optimal torque motor platform requires balancing torque constants ($K_t$), voltage constants ($K_e$), continuous vs. peak thermal limits, and absolute positional feedback integration. Review our standardized torque motor series baseline data below:
| Motor Architecture | Continuous Torque Range | Peak Torque ($T_p$) | Nominal Bus Voltage | Encoder / Feedback Support | Best-Fit Target Application |
|---|---|---|---|---|---|
| Frameless Direct-Drive (BLDC) | 0.5 Nm – 120 Nm | Up to 360 Nm | 24V – 310V DC | BiSS-C, SSI, Optical Absolute | Semiconductor robotics, CNC rotary tables, optical gimbals |
| Robotic Joint Actuators (Harmonic) | 12 Nm – 85 Nm | Up to 210 Nm | 48V DC / CAN FD / EtherCAT | Dual Inductive Encoders | Humanoid AI joint modules, 6-DOF industrial cobot arms |
| EV Direct Traction Hub Motors | 45 Nm – 450 Nm | Up to 1,200 Nm | 48V – 72V / 400V DC | Triple Hall Sensors, Resolver | E-bikes, low-speed EVs, electric forklifts, AGVs |
| Micro Heavy-Duty UAV Actuators | 0.12 Nm – 3.5 Nm | Up to 9.0 Nm | 3S – 12S LiPo (11.1V – 50.4V) | High-KV Magnetic Encoder Options | Cinematic long-range FPV drones, aerial robotics |
As the global market for automation, humanoid robotics, and electrified mobility scales exponentially, procurement executives and senior motion control engineers must align with suppliers capable of staying ahead of key technical trends:
Traditional procurement focused solely on standalone motor frames. Future B2B purchasing favors integrated joint actuators combining frameless torque motors, strain-wave (harmonic) gearing, miniature servo drives, and dual absolute encoders via high-speed CAN FD communication protocols. This reduces cable harness overhead by up to 60%.
Next-generation motor drives employ Silicon Carbide (SiC) and Gallium Nitride (GaN) switching transistors running at carrier frequencies above 100 kHz. Stator winding designs must incorporate high-frequency Litz wire or precision hairpin coils with ultra-low inter-turn capacitance to withstand high $dV/dt$ voltage spikes without insulation breakdown.
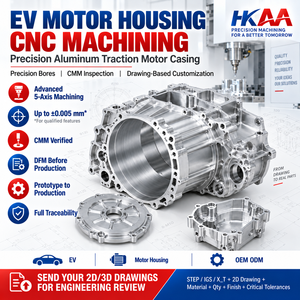
Thermal dissipation dictates continuous torque output. Procurement trends show growing demand for custom aluminum motor casings with integrated helical liquid-cooling jackets (precision CNC turned to ±0.01mm) and direct-to-stator potted thermally conductive epoxies ($>3.0\text{ W/m}\cdot\text{K}$).
The primary engineering challenge in direct-drive torque motor manufacturing is mitigating cogging torque—the non-uniform magnetic attraction between rotor permanent magnets and stator slots that causes unwanted torque ripple at low RPM. Our factory employs three proprietary technical innovations to achieve smooth, sub-arcsecond positioning:
Building upon a historic legacy of fractional horsepower motor excellence, our state-of-the-art facility in China delivers world-class manufacturing execution combined with aggressive cost-competitiveness:
Every raw material batch—from high-permeability magnetic steel laminations to 200°C rated copper magnet wire—undergoes strict incoming quality control (IQC). Finished torque motors undergo 100% automated end-of-line dynamometer testing for torque constants, insulation resistance, and vibration analysis.
Need a custom stack length, special shaft geometry, integrated planetary gearhead, or specific voltage winding constant? Our engineering team delivers validated thermal-magnetic prototypes within 14 business days, complete with complete test curves.
Our products comply with CE, RoHS, REACH, and UL standards. We support flexible procurement terms (FOB, CIF, DDP) serving Fortune 500 equipment builders across North America, Europe, and Asia-Pacific.
Clear, transparent answers to help engineering procurement managers choose the right China torque motor factory.
While both utilize brushless permanent magnet synchronous motor (PMSM) operating principles, a direct-drive torque motor is specialized for low speed and high continuous output torque. Torque motors feature high pole counts (often 12 to 64+ poles), large outer diameter to stack length ratios, and ultra-thin ring configurations. This enables direct coupling to loads without speed-reducing gearboxes, eliminating backlash, mechanical wear, and maintenance requirements.
Yes. Our in-house engineering team routinely modifies copper wire turn counts, wire gauge, and phase connections to tailor the motor speed constant ($K_v$) and torque constant ($K_t$) to your exact DC bus voltage (e.g., 24V, 48V, 310V, 400V). Furthermore, our high-precision CNC machining center provides custom aluminum or steel housings with tolerances down to ±0.01mm, including custom mounting flanges, hollow shafts, keyways, and integrated liquid cooling ports.
We minimize cogging torque through advanced electromagnetic design techniques, including finite element magnetic optimization, fractional-slot concentrated winding topologies, closed stator slot structures, and precisely calculated stator tooth skewing. For ultra-critical applications like surgical robotics or satellite optical payloads, we offer frameless slotless torque motor designs that exhibit zero magnetic cogging torque.
Our manufacturing plant operates under ISO 9001:2015 quality management systems and ISO 13485:2016 medical device standards. Every motor manufactured undergoes 100% end-of-line testing covering hi-pot dielectric strength, insulation resistance, surge testing, back-EMF symmetry, torque constant validation, and absolute zero-point encoder calibration on high-bandwidth dynamometer test benches.
Standard engineering sample prototypes utilizing stocked lamination dies can be built and dispatched within 10 to 14 working days. Fully custom ground-up designs requiring dedicated tooling or specialized CNC motor casings typically require 3 to 4 weeks. High-volume production orders are routinely delivered within 4 to 6 weeks depending on batch volume and shipping arrangements (air freight vs. ocean freight).
Simply click any of our live inquiry buttons on this page to speak directly with an application engineer. Please prepare your system's required continuous torque ($N\cdot m$), peak torque, available supply voltage, outer diameter limits, target operating speed ($RPM$), and estimated annual production quantities for an immediate technical evaluation and formal quote.