PHONE: (847) 253-6000
TOLL FREE: (800) 52-MOTOR
Customizable voltage ratings, ratio configurations, thermal profiles, and feedback integration engineered for continuous-duty OEM applications in San Francisco and global high-tech markets.
The San Francisco Bay Area and Silicon Valley stand as the world's epicenter for advanced artificial intelligence hardware, humanoid robotics, medical biotech devices, autonomous micro-mobility, and aerospace innovation. As engineering teams in South of Market (SoMa), Mission Bay, and surrounding industrial hubs push the physical boundaries of robotic agility and electromechanical integration, traditional off-the-shelf gearmotors frequently fail to satisfy stringent volume constraints, thermal dissipation requirements, dynamic responsiveness, and high power-to-weight ratios. Achieving superior performance demands custom Fractional Horsepower (FHP) motors and integrated gearhead architectures engineered precisely for application-specific duty cycles.
This technical whitepaper examines the critical design methodologies, torque-density optimization algorithms, thermal management practices, and quality standards essential for sourcing custom OEM compact gearmotors. Drawing from over seven decades of manufacturing heritage—originating with American motor building excellence since 1954 and certified under ISO 9001:2015 and medical-grade ISO 13485:2016 quality systems—this guide details how OEM design engineers can eliminate performance bottlenecks, lower total cost of ownership (TCO), and streamline global supply chain sourcing direct to San Francisco prototyping laboratories and manufacturing lines.
Modern motion control in robotics—spanning bi-pedal humanoid actuators, collaborative robot (cobot) joints, autonomous mobile robots (AMRs), and laparoscopic surgical positioners—relies heavily on the synergy between motor stator winding geometry and mechanical gear amplification. The primary design objective is maximizing peak continuous torque output per cubic millimeter while suppressing cogging torque and mechanical backlash.
When selecting a fractional horsepower gearmotor, OEM design teams in San Francisco must evaluate five core technical parameters:
Optimized stator magnetic circuits delivering up to 350% short-term overload torque capacity within ultra-compact NEMA frame envelopes.
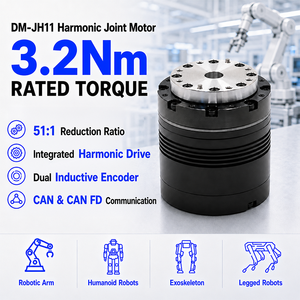
Integrated harmonic gear reducers engineered for absolute positioning accuracy in AI humanoid robotic joints and robotic surgical arms.
Fully compliant with medical device quality management systems and UL recognized component standards for regulated commercial deployment.
Selecting the optimal motor topology requires balancing electrical input requirements against mechanical load profiles. The matrix below outlines typical operational characteristics across our core compact gearmotor and drive platforms engineered for OEM customization.
| Motor Platform Topology | Voltage Options | Rated Torque / Speed | Efficiency Rate | Target San Francisco OEM Application |
|---|---|---|---|---|
| Brushless DC (BLDC) Parallel Shaft | 12V, 24V, 48V, 310V DC | 0.5 Nm – 45 Nm / 50–3000 RPM | 88% – 94% | AMR Drive Wheels, AGV Conveyors, Lab Automation |
| Harmonic Joint Actuator (CAN-FD) | 24V, 48V Bus Voltage | 12 Nm – 180 Nm / 10–120 RPM | 78% – 86% | Humanoid AI Arm Joints, Exoskeletons, Surgical Robotics |
| PMDC Right Angle Gearmotor | 12V, 24V, 36V DC | 1.2 Nm – 35 Nm / 15–400 RPM | 68% – 82% | Battery Micro-Mobility, Access Control, Vending Drives |
| High-Power Traction Transaxle | 48V, 60V, 72V DC | 50 Nm – 450 Nm / 200–1200 RPM | 90% – 95% | Electric Forklifts, Low-Speed EVs, Airport Tuggers |
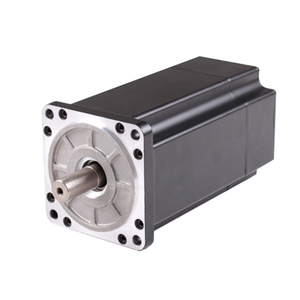
| Precision Hybrid Stepper Gearhead | 24V–48V Chopper Drive | 0.2 Nm – 15 Nm / 0.1–300 RPM | 72% – 80% | Bio-Pharma Dosing Pumps, Optical Stage Positioning |
| UAV Brushless Propulsion Drive | 3S – 12S LiPo (11V – 50V) | High Thrust Output / Up to 15,000 RPM | 91% – 96% | Cinematic UAVs, Delivery Drones, Defense Inspection |
San Francisco's unique industrial profile combines cutting-edge AI software with physical hardware engineering. Custom OEM compact gearmotors serve as the critical muscle behind these groundbreaking local innovations:
San Francisco's robotics incubators in SoMa and Dogpatch require compact joint motors with ultra-low backlash harmonic reducers and embedded dual inductive encoders. These drives execute real-time impedance control, allowing humanoid arms and hands to perform intricate handling tasks inside hazardous environments and domestic automation testbeds.
Mission Bay's biotechnology clusters rely on ISO 13485 certified BLDC and stepper gearmotors for automated liquid handlers, high-throughput blood centrifuges, and minimally invasive surgical tools. High winding efficiency minimizes heat transfer to sensitive biological reagents, while sealed IP67 enclosures resist aggressive chemical washdowns.
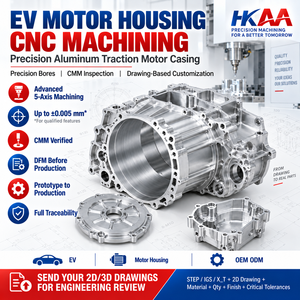
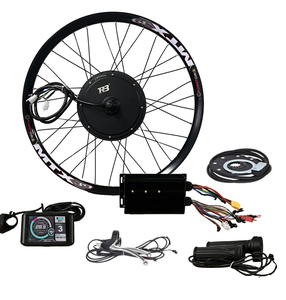
From San Francisco's steep urban grade ascents to last-mile electric delivery pods across the Bay Bridge, custom MTX hub motors and integrated 4kW EV transaxles deliver massive starting torque. CNC-machined lightweight aluminum casings ensure high power density while enduring harsh coastal fog humidity and vibrational stress.
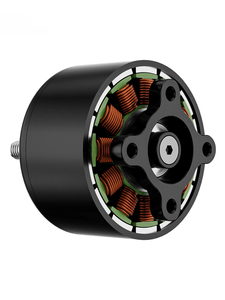
Flight-testing operations based around Treasure Island and Alameda demanding high-KV, dynamically balanced brushless UAV motors. Using 0.2mm silicon steel laminations and Japanese NMB precision bearings, these drone motors optimize thermal headroom for long-duration aerial footage, infrastructure monitoring, and payload delivery.
Fulfillment centers along the Peninsula leverage 24V/48V BLDC parallel-shaft gearmotors inside compact Autonomous Mobile Robots (AMRs). Integrated magnetic brakes and high radial shaft load support enable continuous 24/7 material handling across automated distribution hubs.
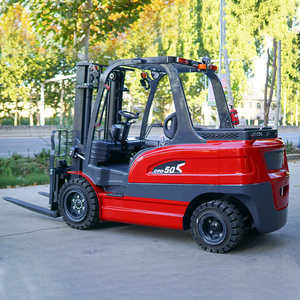
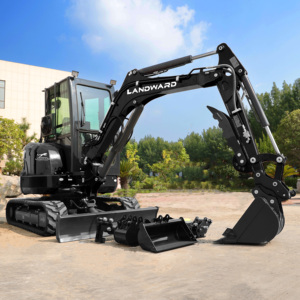
Custom hydraulic-replacement gear drives and compact track actuation systems powering 1–3.5 ton micro excavators and electric forklifts used in San Francisco urban renovation projects where zero emissions and low noise profiles are strictly enforced by municipal regulations.
To assist San Francisco engineering procurement leads, component buyers, and technical founders, our senior engineering team addresses the most common inquiry scenarios:
A: Standard mechanical and electrical modifications (such as custom shaft flats, lead wire pinouts, or modified gear ratios) typically ship within 2 to 3 weeks. Full custom motor frame toolings or dynamic harmonic joint prototypes are delivered within 4 to 6 weeks directly to Bay Area prototyping facilities via expedited air freight.
A: All custom gearmotors exported to California clients are fully compliant with RoHS 3, REACH, and CE safety standards. Underwriters Laboratories (UL) recognized insulation systems (Class B, F, or H) are available for appliances, commercial equipment, and medical devices governed by UL 1004 specifications.
A: Yes. For heavy-duty wheel drives, micro excavators, or cantilevered robotic joints, we engineer reinforced gearbox housings utilizing dual deep-groove ball bearings, needle roller bearings, or tapered roller bearings capable of absorbing radial loads exceeding 3,000 N.
A: Every design undergoes 100% dynamometer load testing, thermal rise measurement under duty cycle loading, acoustic decibel analysis, magnetic flux verification, and HALT (Highly Accelerated Life Testing) within our ISO 9001:2015 certified facilities before releasing tooling for volume manufacturing.
A: Harmonic joint actuators eliminate gear backlash (< 30 arc-sec vs 10–15 arc-min in standard planetary gearheads) and provide extreme single-stage reduction ratios (up to 160:1) in a thin pancake form factor, making them essential for robotic elbow, shoulder, and wrist joints.
A: Absolutely. We support hardware startups from early prototype proof-of-concept stages (10–50 units) through to high-volume automated production runs (100,000+ units annually) with scalable pricing structures and dedicated application engineering support.
In the motion control industry, true technical authority is forged over decades of rigorous field deployment. Since 1954, our manufacturing infrastructure has maintained a single-minded commitment to motor quality—summed up in our founding ethos: "Quality Is Our Future."
Operating out of state-of-the-art facilities equipped with automated coil winding machinery, high-precision CNC gear hobbing, cleanroom sub-assembly zones, and automated end-of-line testing rigs, our engineering operations combine traditional craftsmanship with futuristic automation. Holding dual UL Registered Firm certifications for ISO 9001:2015 (Quality Management Systems) and ISO 13485:2016 (Medical Device Component Manufacturing), we provide complete material lot traceability, rigid change control protocols, and comprehensive engineering documentation (including 3D STEP files, thermal curves, speed-torque curves, and reliability reports).
Whether your application demands low-speed high-torque EV propulsion, whisper-quiet laboratory fluid metering, zero-backlash AI robotic joint control, or ultra-light drone propulsion, our application engineers partner directly with your engineering team to transform technical requirements into validated, production-ready motion systems delivered on-time to San Francisco, North America, Europe, and worldwide markets.
Contact our application engineering team today to review your torque, gear ratio, thermal, and dimensional specifications. Receive detailed 3D CAD models, speed-torque curves, and prototype quotes within 24 hours.